Tennis Buddy
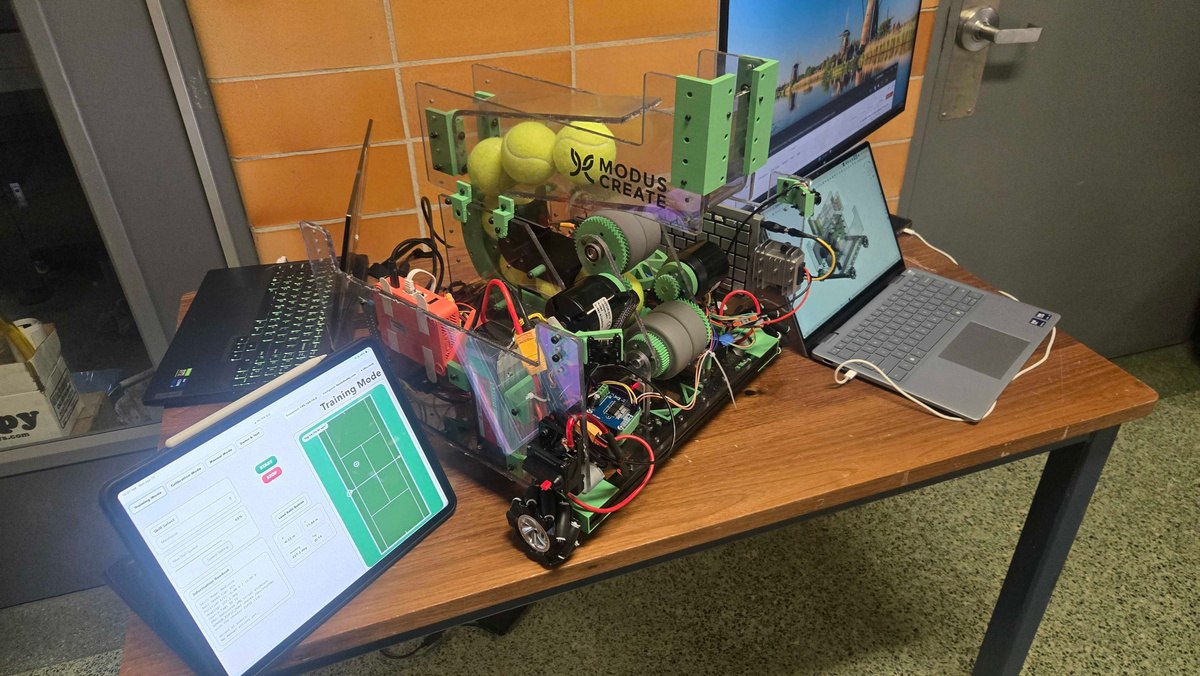
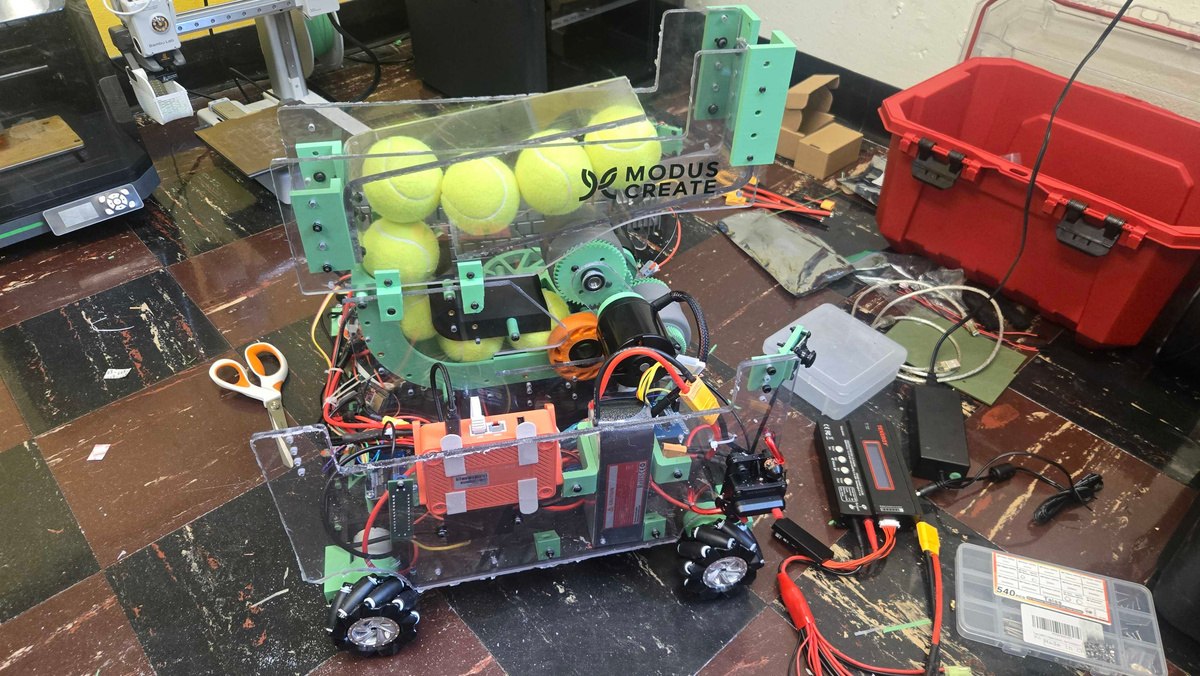
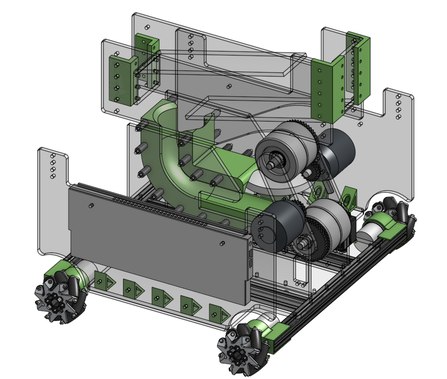
We built a tennis training robot in 24 hours, including machined polycarbonate plates. Tennis Buddy combines a mecanum drivetrain, a flywheel shooter, an adjustable hood, and gravity-fed loading, with onboard cameras and a laptop interface.
I led the robot design and took the shooter and hood from concept to finished hardware. I also helped integrate the drivetrain, loading, and controls within the deadline.
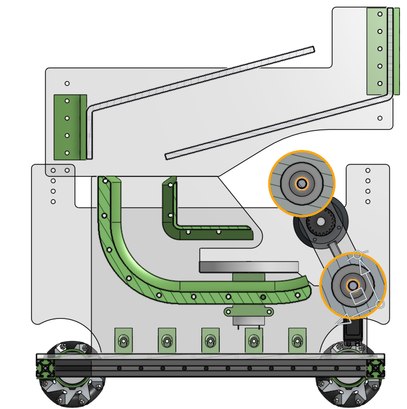
Two 4,000 W BLDC skateboard motors drive the flywheels. Different wheel speeds produce topspin or backspin; matching them produces a flat shot. A compliant-wheel indexer feeds one ball at a time from the nine-ball magazine.
The hood is the part I'm most proud of. A servo drives it through herringbone gears to reduce backlash and repeatably adjust launch angle in a tight space. Mecanum wheels provide omnidirectional movement, and an ESP32 handles Wi-Fi control.